

BangBoots: An Expressive Educational Robot Moving Toward Custom PCBs
BANGBOOTS PROJECT STORY
BangBoots is a student-led educational robotics project from the Dominican Republic. Its goal is to build a small expressive, mobile and conversational robot that combines an animated face, voice, camera-based perception, safe movement, sensors and a companion application. The project is non-commercial and is being developed as a transparent engineering and learning process.
CURRENTLY VALIDATED
The expressive software, BangboOS, already runs on real ESP32-WROOM-32E test hardware using a 3.5-inch CYD board. It provides a launcher, modular applications, touch and physical-button control, microSD resources, audio, persistent settings, Wi-Fi screen streaming, 11 faces and 10 expressions. Testing on the physical board shows stable 60 FPS at approximately 60 percent CPU usage. The CYD is only a low-cost development bench, not the final robot controller.
PLANNED ARCHITECTURE
The expression and perception layer will be migrated to a more capable ESP32 platform after hardware compatibility tests. Movement and local safety will be handled independently by an Arduino UNO Q running the ROS-related stack, connected through a wired and versioned protocol. Motor stops, watchdogs, link-loss behavior, current protection and emergency shutdown remain local and never depend on cloud services.
WHY CUSTOM PCBS ARE NEEDED
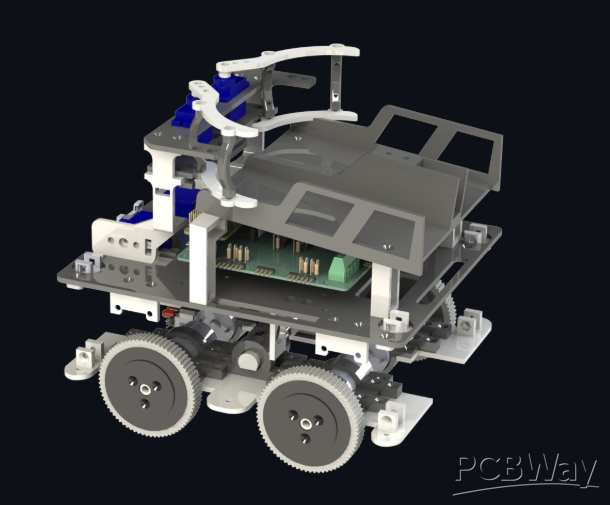
After the first modules are validated, BangBoots will need purpose-built PCBs for reliable power distribution, protected logic and actuator power paths, board-to-board communication, sensor and encoder connections, audio and display integration, service connectors and repeatable internal wiring. The body and mechanical structure will be produced locally; this sponsorship request is specifically for PCB prototyping and manufacturing support.
DEVELOPMENT ROADMAP
The work proceeds through measurable phases: preserve and port BangboOS; validate display, touch, SD, audio and camera; define the wired expression-to-motion protocol; build a stable mobile base with encoders, IMU, bumpers, distance and drop-off sensors; add limited-force gestures and local Spanish voice behavior; then test prepared objects, bounded missions and LIDAR navigation. Each stage requires recorded measurements and safe failure behavior before the next stage begins.
SPONSORSHIP REQUEST
I am seeking prototype PCB manufacturing support, fabrication coupons and DFM feedback for the first BangBoots unit as each board revision becomes ready. Initial quantities will be small and intended for bring-up, measurement and documented iteration. Shipping assistance to the Dominican Republic would also be valuable.
DOCUMENTATION AND ACKNOWLEDGEMENT
I will document schematics, design decisions, fabrication revisions, board bring-up, measurements, failures, corrections, photos and demonstrations. PCBWay will be acknowledged clearly as a PCB fabrication supporter. The repository is currently private while the project is organized, but review access and project materials can be provided on request.
WHO I AM
I am Jose Nicolas Sanchez Zorrilla, a mechatronics student at Instituto Tecnologico de las Americas (ITLA) in the Dominican Republic and team leader of BangBoots. I am building the project as an educational initiative and will not present planned or untested functions as completed.
WORDS TO PCBWAY
Support for even one documented PCB prototype phase would make a meaningful difference. Thank you for considering BangBoots and for helping a student project move from validated bench software toward safe, maintainable and reproducible robot hardware.
Apply for sponsorship >>- Comments(0)
- Likes(0)