
|
KiCad 8.0KiCad
|
|

|
STM32CubeIDESTMicroelectronics
|
REMI-Rapid Exploration and Maze Interpretation
Project Description:
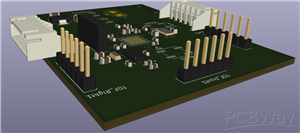
This is a personal Micromouse project built around the STM32F411 microcontroller, designed to autonomously solve mazes. It features precise orientation tracking with the BNO055 IMU and accurate distance measurement using VL53L0X sensors. The custom PCB integrates these components along with a TI motor driver to run the flood-fill algorithm for efficient navigation.
I undertook this project to enhance my skills in robotics and embedded systems, while tackling the challenge of autonomous navigation. It’s a great way to bring theoretical concepts to life through practical application.
How It Works:
Sensors: VL53L0X modules measure distances to walls, and the BNO055 IMU tracks orientation.
Microcontroller: The STM32F411 processes the sensor data and runs the flood-fill algorithm to find the shortest path.
Motors: The TI motor driver controls the motors based on feedback from sensors, ensuring precise movement.
REMI-Rapid Exploration and Maze Interpretation


Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(1)
- Likes(0)
 More by Engineer
-
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
753 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
428 0 1 -
Programmable Mist Maker - XIAO / QT PY Extension
2877 2 3 -
RadioHAT - Raspberry Pi radio development platform
2463 0 4 -
-
-
-
ARPS-2 – Arduino-Compatible Robot Project Shield for Arduino UNO
4546 0 6