

|
|
mearm printable parts |
x 1 | |
|
SG90 Micro Servo motors |
x 4 | |
|
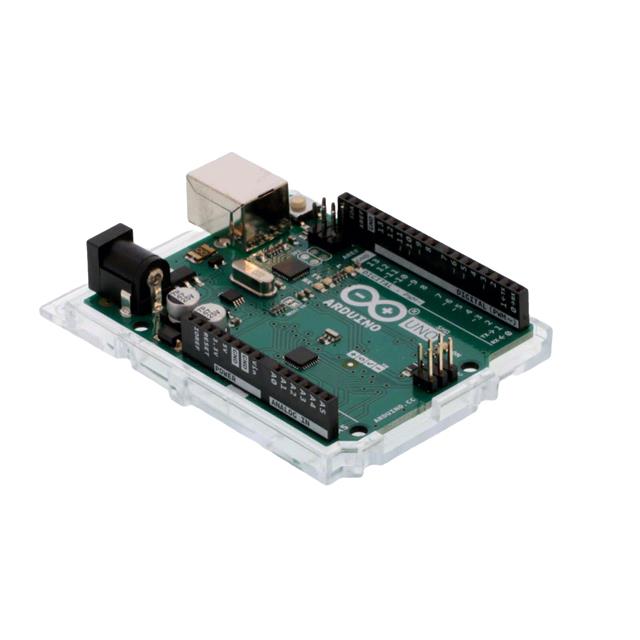
A000073Arduino
|
x 1 | |
|
|
driver shield |
x 1 |

|
arduino IDEArduino
|
|

|
VS Code |
TrisVision MeArm
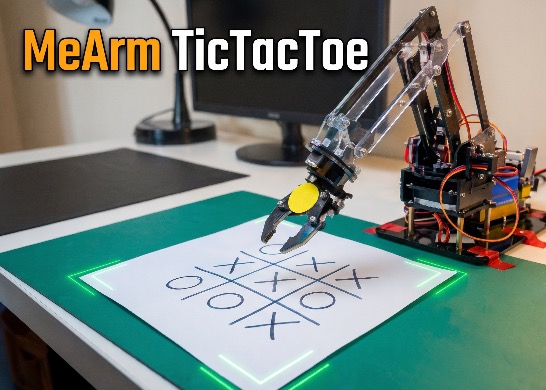
The project consists of the development of an interactive robotic system based on a 4DOF arm with a parallelogram structure (MeArm). The system is capable of challenging a human to a game of Tic-Tac-Toe, identifying moves (X) on a sheet of paper via a webcam and physically responding on the board (O).The software is written in Python and communicates with a microcontroller via a BT-24 Bluetooth Low Energy module.
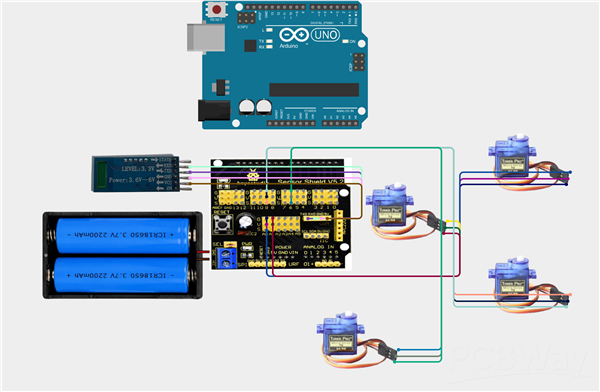
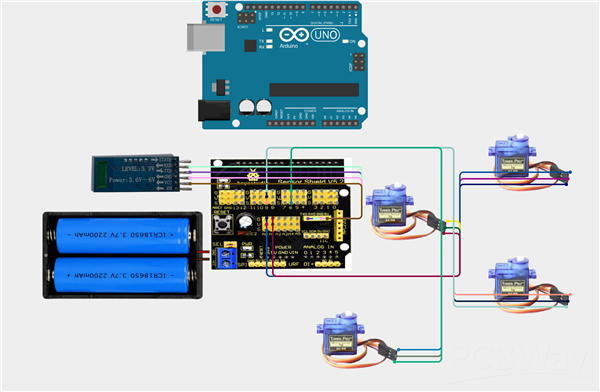
Wiring (-> motorshield pins)
| Servo | Funzione | Pin |
| 1 | Base | A1 |
| 2 | Shoulder | A0 |
| 3 | Elbow | 6 |
| 4 | Gripper | 9 |
| 5 | BT Module | v,g,rx,tx |
Software
The architecture is modular, separating the vision logic, artificial intelligence, and hardware communication:
Vision/Main (trisvision.py): Uses OpenCV to track the playing field, recognize symbols (X and O), and render graphics in Mixed Reality.
Logic (tris_logica.py): Contains the algorithm (Minimax) to calculate the robot's move.
Communication (ble_link.py, config.py): Interface using the `bleak` library for asynchronous sending of commands (servo motor angles) to the Arduino via Bluetooth.
Calibration
To allow the robot to interact accurately with the real world, several calibration phases were necessary.
Spatial Calibration
Since the camera frames the table, the image has perspective distortions. The software dynamically searches for the 4 sides of the white paper and applies perspective correction (warpPerspective). By pressing the 'B'*key (Memory Lock), the system freezes the transformation matrix, allowing the robot to enter the scene without disrupting the geometric recognition of the board.
Color Calibration
Target objects were isolated from the environment by adjusting the Min/Max thresholds for Hue (H), Saturation (S), and Value (V). In this case, the color of a yellow circle glued to the gripper was calibrated (calibra_EE.py), which is essential for visually tracking the position of the end-effector.
Electromechanical Calibration
The hardware (SG90 micro-servo motors) has significant mechanical tolerances. Instead of using complex kinematic calculations, the system uses a static mapping (`MAPPA_CASELLE`) where a safe combination of angles (Base, Shoulder, Elbow) has been saved for each of the 9 Tic-Tac-Toe squares. This decouples the mathematical model from the physical problem, offloading hardware imperfections onto a manually tunable configuration file (via test_ble.py).
Problem Solving
Mechanical Limits and Motor Strain
The parallelogram structure of the arm made it difficult to maintain a constant height, risking crashing the gripper into the table or stripping the motors' gears.
Solution (Mixed Reality): The robot does not physically manipulate objects. It travels at a safe height, hovering over the field. The webcam tracks the yellow dot and, once positioned, the computer draws a virtual 'O' on the screen, blending the physical movement with a digital response.
Visual Occlusion and False Positives
The black acrylic of the arm, upon entering the frame, was falsely detected by the Otsu filter as an 'X'. Furthermore, shadows and folds in the paper created visual noise.
Solution (Sensor Muting): The software disables the search for 'X's during the robot's turn, ignoring the moving hardware.
Conclusion
The project demonstrates the integration of an advanced computer vision system with low-cost hardware control. The inherent limitations of budget mechanics were entirely compensated for through rigorous software design and the creative use of Mixed Reality.
TrisVision MeArm


Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(0)
- Likes(2)
More by Luca Fagioli
-
 MeArm Connect4 Simulation
The project consists of the development of an end-to-end physics simulator of a robotic arm (MeArm) ...
-
 MeArm Hand Gesture Control
A webcam watches your hands. Python (using mediapipe) tracks the landmarks of both hands in real-tim...
-
 MeArm PickPlace
The project involves the development of an autonomous robotic system based on a 4DOF arm with a para...
-
 MeArm-ML-PyBullet
A 4DOF trained in simulation using reinforcement learning to reach a target, and transferred via ser...
-
 TrisVision MeArm
The project consists of the development of an interactive robotic system based on a 4DOF arm with a ...
-
 4WD SLAM Radar 2D Robot Car
An autonomous 4-wheel drive explorer robot based on Arduino UNO R4 WiFi , designed to navigate throu...
-
-
-
AudioLink – USB & Bluetooth LE Audio / Auracast Receiver with Balanced Line Outputs (nRF5340)
278 0 1 -
-
-
-
Émetteur Récepteur Optique Expérimental (communication UART ATtiny + fibre optique)
357 0 1 -
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
1428 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
797 0 1