

|
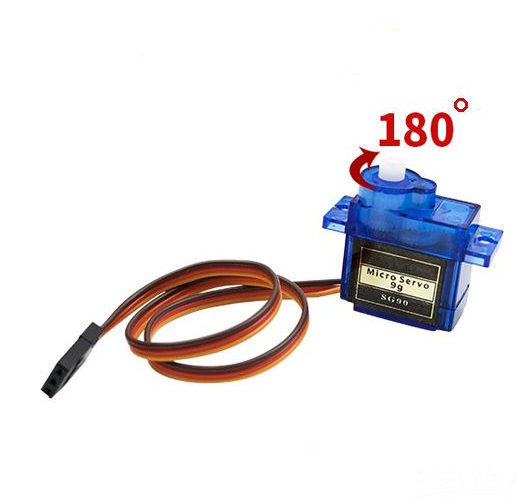
SG90 Micro Servo motors |
x 4 | |
|
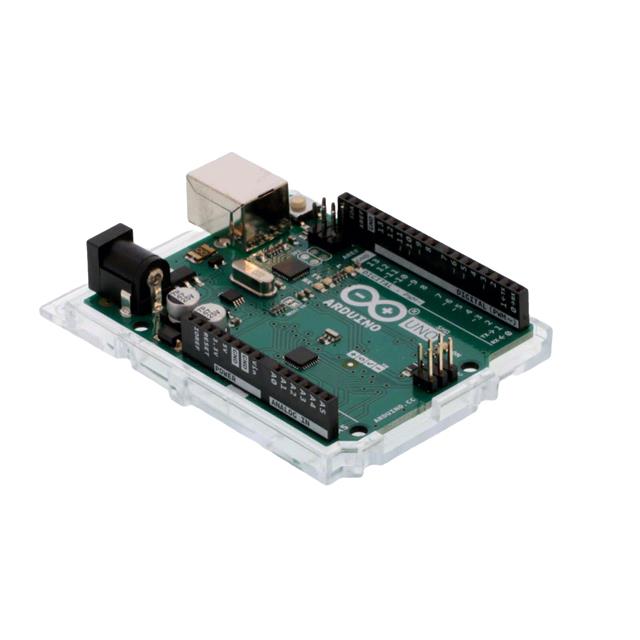
A000073Arduino
|
x 1 | |
|
|
motor shield |
x 1 | |
|
|
mearm printable parts |
x 1 |
MeArm-ML-PyBullet
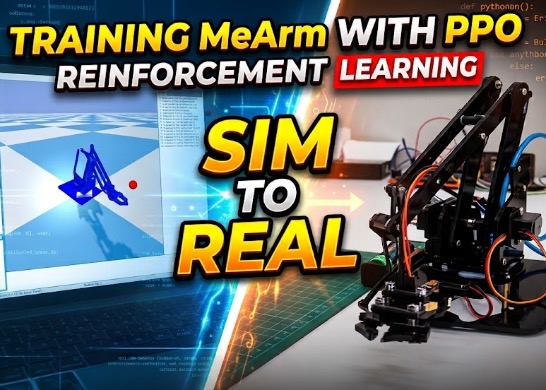
A 4DOF trained in simulation using reinforcement learning to reach a target, and transferred via serial to the physical arm. Task: reach — moving the tip of the arm (tool) towards a red dot generated within the arm's real workspace, using PPO (Proximal Policy Optimization, Stable-Baselines3) on a PyBullet model built from the real URDF/meshes of the mechanism.
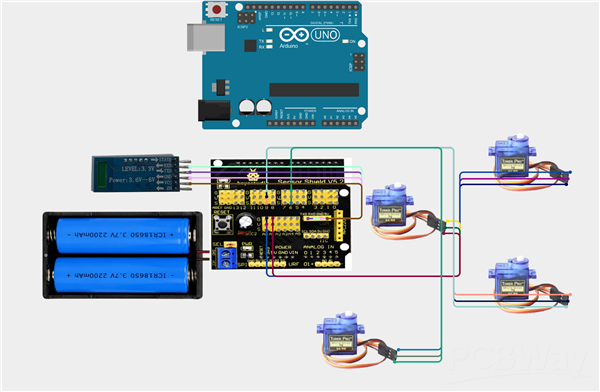
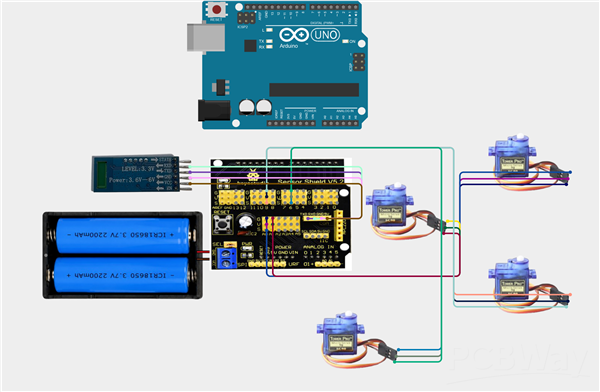
Wiring (-> motorshield pins)
| Servo | Funzione | Pin |
| 1 | Base | A1 |
| 2 | Shoulder | A0 |
| 3 | Elbow | 6 |
| 4 | Gripper | 9 |
| 5 | BT Module | v,g,rx,tx |
Neural network
An input layer with 17 neurons (one for each observation value: 4 (positions) + 4 (velocities) + 3 (ee_pos) + 3 (target_pos) + 3 (delta_pos))
An output layer with 4 neurons (one for each motor).
SOFTWARE
Mearm_real_env.py
Gymnasium environment for the MeArm/Keyestudio KS0198X robotic arm, simulated in PyBullet from the real URDF (URDF and mashes available on GitHub).
Serial_bridge.py
Sim-to-real bridge: reads a trained policy and sends the corresponding servo angles to the physical arm via serial.
Train.py
PPO training (with linear reward) of the 'reach' task on the real MeArm model.Run on an M1 mac for 1M steps across 4 parallel environments (you can use even more steps if necessary for your specific case). PPO takes the data from all 4, averages it, and updates the weights much more stably.
To monitor training progress with TensorBoard, open the terminal:tensorboard --logdir ./tb_logs/"
Evaluate.py
Loads the trained model and shows it in action within the PyBullet GUI.
MeArm-ML-PyBullet


Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(0)
- Likes(1)
More by Luca Fagioli
-
 MeArm Connect4 Simulation
The project consists of the development of an end-to-end physics simulator of a robotic arm (MeArm) ...
-
 MeArm Hand Gesture Control
A webcam watches your hands. Python (using mediapipe) tracks the landmarks of both hands in real-tim...
-
 MeArm PickPlace
The project involves the development of an autonomous robotic system based on a 4DOF arm with a para...
-
 MeArm-ML-PyBullet
A 4DOF trained in simulation using reinforcement learning to reach a target, and transferred via ser...
-
 TrisVision MeArm
The project consists of the development of an interactive robotic system based on a 4DOF arm with a ...
-
 4WD SLAM Radar 2D Robot Car
An autonomous 4-wheel drive explorer robot based on Arduino UNO R4 WiFi , designed to navigate throu...
-
-
-
AudioLink – USB & Bluetooth LE Audio / Auracast Receiver with Balanced Line Outputs (nRF5340)
278 0 1 -
-
-
-
Émetteur Récepteur Optique Expérimental (communication UART ATtiny + fibre optique)
357 0 1 -
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
1428 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
797 0 1