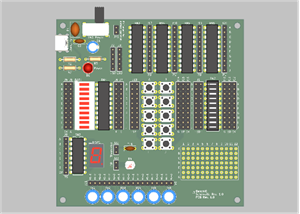


 Top Solder Mask
 Top Overlay
 Top Copper Layer
 Keep Out Layer
 Bottom Solder Mask
 Bottom Overlay
 Bottom Copper Layer
 Bottom
 Top
Christmas Themed Quadcopter Design
### DESCRIPTION
This is the base design for a quadcopter themed in a christmas scheme.
### TECHNICAL DETAILS / COMPONENTS
This design uses a MSP430FR5994 microcontroller to operate, and contains a proximity sensor and accelerometer to ensure stable flight. The QR Code on the quadcopter links to the GUTHUB for the project.
### LEARN / TOPIC / BUILD INSTRUCTIONS
In order to build this, parts must be ordered and assembled using a pick & place machine. The code which needs to be written for this quadcopter includes I2C communication between the sensors and PID Control for the motors.
Christmas Themed Quadcopter Design
Project images are for reference only. Actual production is based on the manufacturing files on the project page.
Please review the designer's notes (e.g., PCB thickness) and select the appropriate options.
PCBWay is not responsible
for issues caused by unsuitable parameter selections.
For more important ordering information, please refer to
Read More


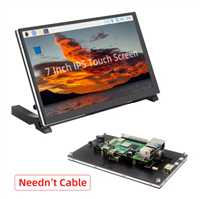
Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(0)
- Likes(2)
- 1 USER VOTES
- YOUR VOTE 0.00 0.00
-
10design
-
10usability
-
10creativity
-
10content
More by Nick Gorab
-
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
858 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
503 0 1 -
Programmable Mist Maker - XIAO / QT PY Extension
2971 2 3 -
RadioHAT - Raspberry Pi radio development platform
2517 0 4 -
-
-
-
ARPS-2 – Arduino-Compatible Robot Project Shield for Arduino UNO
4591 0 6