|
|
Blender |
|

|
ONSHAPE |
|
|
|
Onshape to robot |
|
|
|
pybullet |
miniature 6 axis robot arm
Project Overview
I started this project to look under the hood of industrial robotics—moving beyond high-level abstractions to master kinematics, embedded architecture, and motion control from the ground up. While funding constraints mean the full physical arm is still being realized, the project has already served as a deep dive into mechatronic design and simulation.
The hardware is designed around NEMA 17 steppers paired with Sweep Dynamics Cricket Drive MK II cycloidal gearboxes and Makerbase MKS SERVO42D closed-loop drivers, communicating over CAN bus to a Teensy 4.1 microcontroller. With a reach of ~300 mm, the arm is compact enough for a desktop setup, yet engineered with industrial rigor: closed-loop control and high-reduction gearboxes deliver exceptional torque density and fluid motion.
Accomplishments to Date:
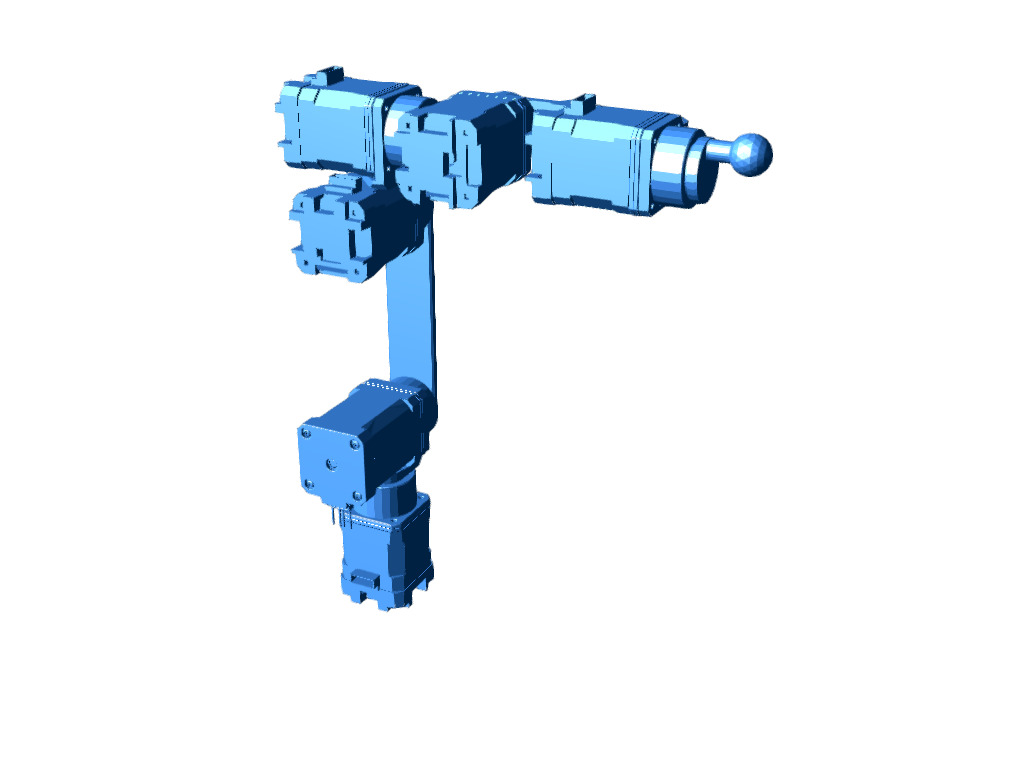
- Parametric Mechanical Design: Complete 6-axis kinematic assembly modeled in Onshape.
- First-Principles Kinematics: Fully derived Denavit-Hartenberg (DH) parameters, forward kinematics, and analytical inverse kinematics (IK).
- Physics & Kinematic Simulation: Automated URDF pipeline from Onshape into PyBullet for kinematic validation and collision modeling.
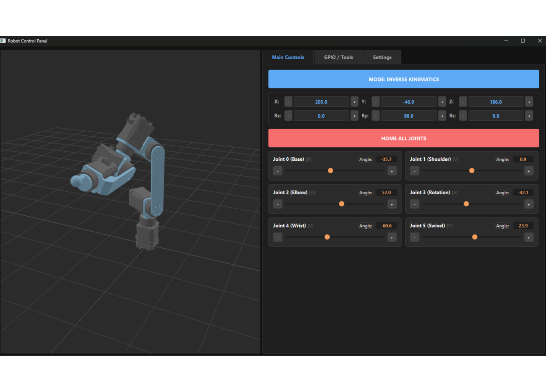
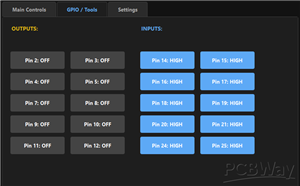
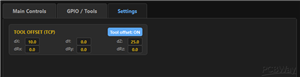
- Custom Control Software: Python-based GUI featuring an interactive 3D virtual twin with real-time pose visualization and trajectory generation (featured in today's demo).
- Physical Hardware Validation: Operational single-axis testbed running the Teensy 4.1, MKS SERVO42D closed-loop driver, and cycloidal gear unit driven live by the Python control stack over CAN bus.
Future Roadmap:
- Full Physical Assembly: Machine and print remaining joint components to build out all 6 degrees of freedom.
- End-Effector Integration: Design and prototype a custom gripper.
- ROS Integration & Autonomy: Expand the control pipeline into ROS/ROS 2 for trajectory optimization, collision avoidance, and vision-guided pick-and-place (a primary destination for contest prize).
- Control Stack Development: Advance the native Python suite to support multi-axis synchronized interpolation and custom trajectory profiles.
miniature 6 axis robot arm
Project images are for reference only. Actual production is based on the manufacturing files on the project page.
Please review the designer's notes (e.g., PCB thickness) and select the appropriate options.
PCBWay is not responsible
for issues caused by unsuitable parameter selections.
For more important ordering information, please refer to
Read More


Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(0)
- Likes(0)
 More by Engineer
-
-
AudioLink – USB & Bluetooth LE Audio / Auracast Receiver with Balanced Line Outputs (nRF5340)
75 0 0 -
-
-
-
Émetteur Récepteur Optique Expérimental (communication UART ATtiny + fibre optique)
281 0 1 -
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
1224 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
711 0 1 -
Programmable Mist Maker - XIAO / QT PY Extension
3217 2 4