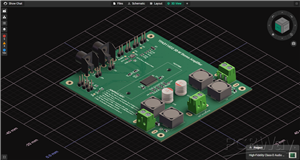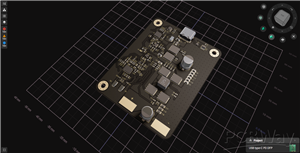


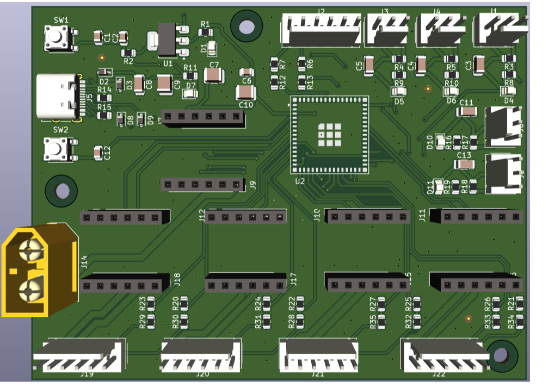
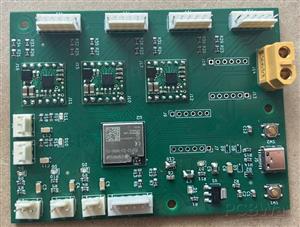
motor control PCB
The first version of the hexapod PCB was designed as a centralized control and actuator interface board for the robot. It was based on an ESP32-S3-MINI-1U microcontroller and was responsible for controlling the DC motors, reading their encoders, monitoring limit switches, and managing communication with the higher-level robotic system.
The board integrated five DRV8256P motor drivers to control up to five Pololu 37D 12 V DC gear motors with 131.25:1 gearboxes and quadrature encoders. Motor control was implemented through PWM and direction signals, while the encoder feedback was used to determine joint position and velocity.
The PCB also included power distribution from a 3S LiPo battery, voltage regulation for the digital electronics, logic-level conversion for the encoder signals, and connectors for motors, encoders, limit switches, communication, and power.
The main objective of this design was to reduce wiring and provide a compact interface between the robot's high-level computer and its low-level actuators. The PCB served as the main low-level control layer, receiving commands from the external computer and converting them into motor control signals while continuously providing encoder feedback.
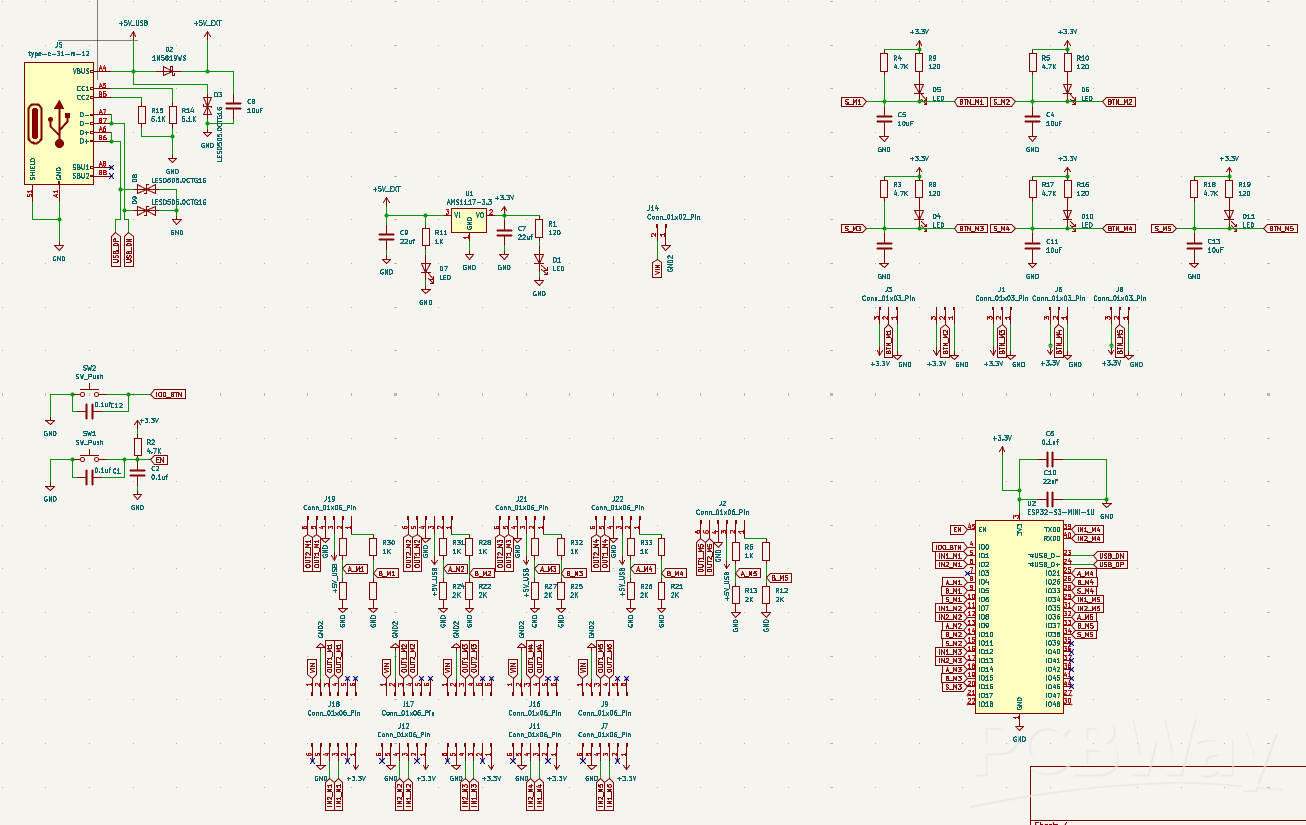
motor control PCB
Project images are for reference only. Actual production is based on the manufacturing files on the project page.
Please review the designer's notes (e.g., PCB thickness) and select the appropriate options.
PCBWay is not responsible
for issues caused by unsuitable parameter selections.
For more important ordering information, please refer to
Read More


Raspberry Pi 5 7 Inch Touch Screen IPS 1024x600 HD LCD HDMI-compatible Display for RPI 4B 3B+ OPI 5 AIDA64 PC Secondary Screen(Without Speaker)
BUY NOW


- Comments(0)
- Likes(1)
More by Ivan Sanmartin

-
-
AudioLink – USB & Bluetooth LE Audio / Auracast Receiver with Balanced Line Outputs (nRF5340)
135 0 0 -
-
-
-
Émetteur Récepteur Optique Expérimental (communication UART ATtiny + fibre optique)
314 0 1 -
SmallOLED - Live PC Stats, Animated Clocks & Audio Visualizer
1308 0 3 -
"Talking Multimeter": Arduino-Based Speech Add-on for Multimeters with SCPI Protocol
745 0 1 -
Programmable Mist Maker - XIAO / QT PY Extension
3274 2 4